Dance Training on Unitree G1
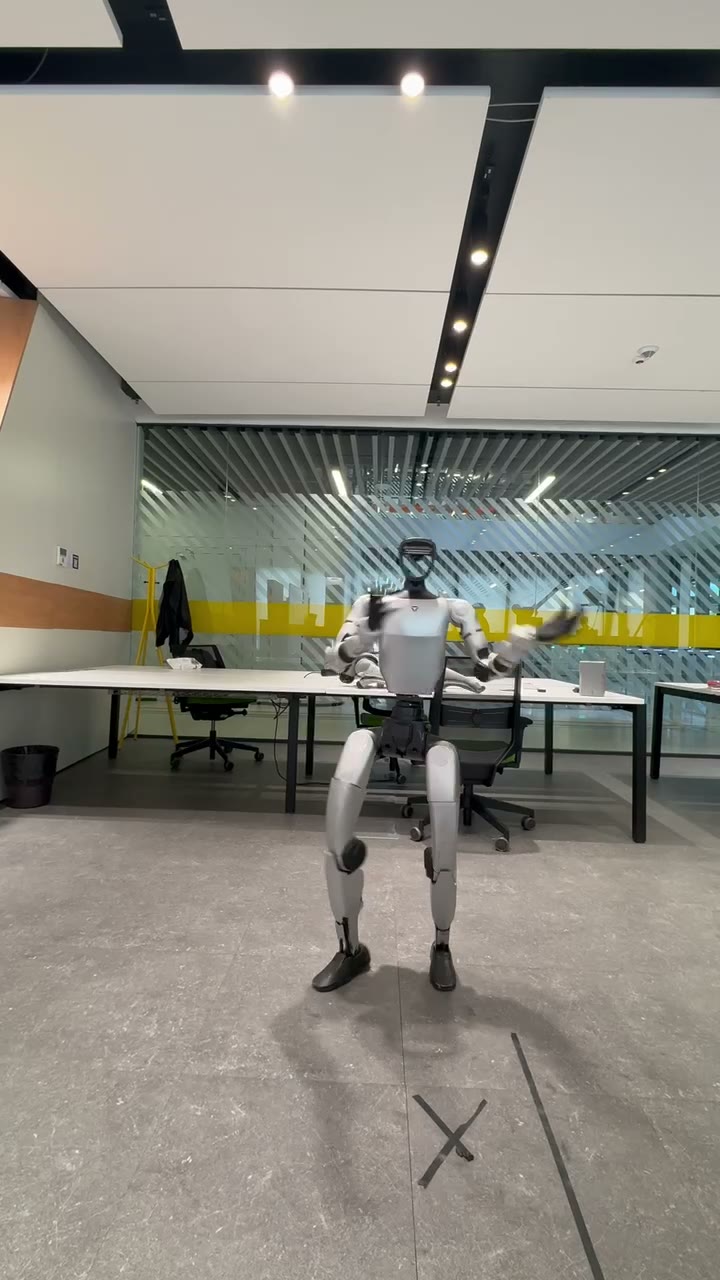
RL-trained dance policies on the G1 — including the traditional Kazakh dance Kara Jorga.
- RL
- Motion Retargeting
- Sim-to-Real
- Isaac Lab
Overview
We trained the Unitree G1 to dance — and taught it Kara Jorga, a traditional Kazakh dance with distinctive shoulder and footwork rhythms.
Human dance recordings were retargeted to the robot and turned into robust RL policies that run on real hardware.
The Challenge
Dance moves push a humanoid close to its balance and torque limits.
Kara Jorga's style lives in subtle shoulder and arm motion that is easy to lose during retargeting.
Our Approach
Captured reference motion from dancers and retargeted it to the G1 skeleton while preserving style-defining joints.
Trained motion-imitation policies in Isaac Lab with domain randomization for sim-to-real transfer.
Iterated on the real robot to tune timing, music sync and safety margins.
Results
- Kara Jorga performed on a real G1 (placeholder — add event or video link)
- A reusable retargeting + imitation pipeline for new choreographies
Tech Stack
- Unitree G1
- Isaac Lab
- Isaac Sim
- PyTorch
- Motion capture