Skip to content

Robotics R&D Services

Your outsourced robotics team for humanoids and robot dogs — from first prototype to a robot that works every day.

Engineer programming a humanoid robot

01 — Service

Secondary Development

For companies, labs and integrators who already own a robot and need it to do something specific. We write the software on top of the manufacturer's SDK — from low-level control to the app your operators touch.

  • Locomotion and reinforcement-learning policies trained in Isaac Lab
  • Manipulation with grippers and dexterous hands
  • Whole-body teleoperation for demos and data collection
  • VLA model training on your own demonstrations
  • Sim-to-real transfer, ROS 2 integration and custom apps

For: Companies, research labs and system integrators
Team reviewing a robotics architecture diagram

02 — Service

Robotics Consulting

An independent second opinion from engineers who work with these platforms every day. We help you decide what to buy, what to build and what to skip.

  • Platform selection — which robot for which task
  • Technical feasibility studies and proof-of-concept scoping
  • Software architecture reviews
  • R&D roadmaps with realistic milestones
  • Team augmentation — our engineers inside your team

For: Founders, R&D managers and innovation teams

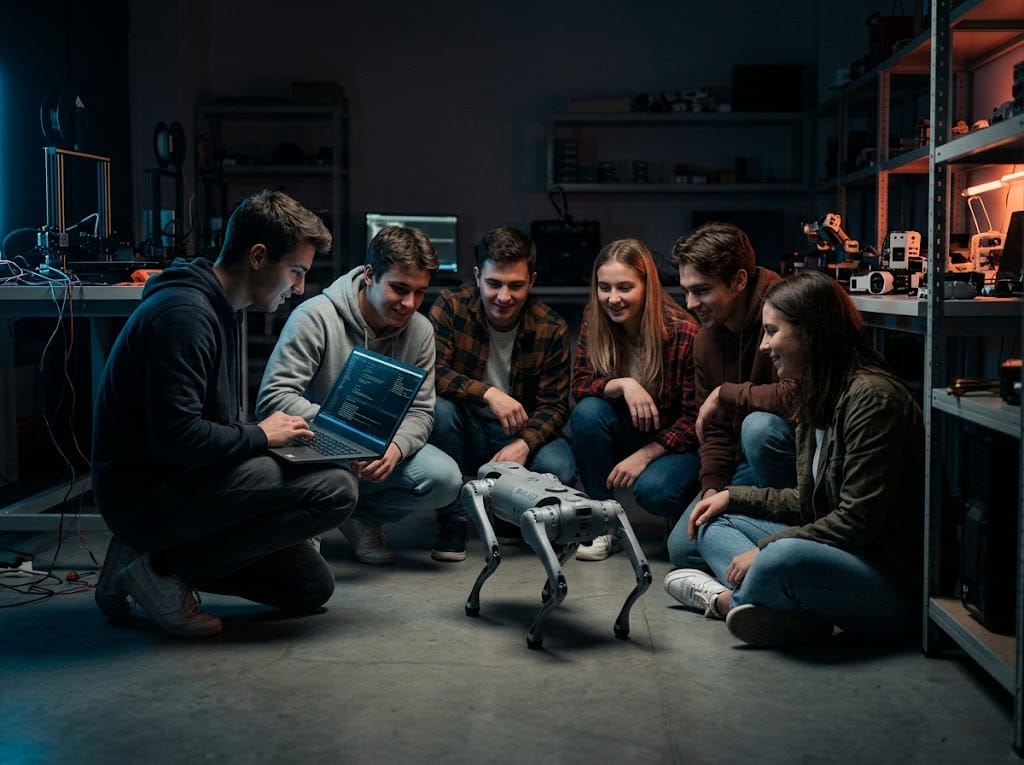
Students working with a quadruped robot in a classroom

03 — Service

Robotics Education

Structured, hands-on programs built from our own project work. Every course ends with something running — in simulation or on a real robot.

  • Humanoid programming on a real Unitree G1 — now enrolling
  • Quadruped programming on the Unitree Go2
  • Reinforcement learning with Isaac Lab
  • Simulation first (MuJoCo, Isaac), then real hardware
  • For universities, companies and individuals

For: Universities, companies and individual learners

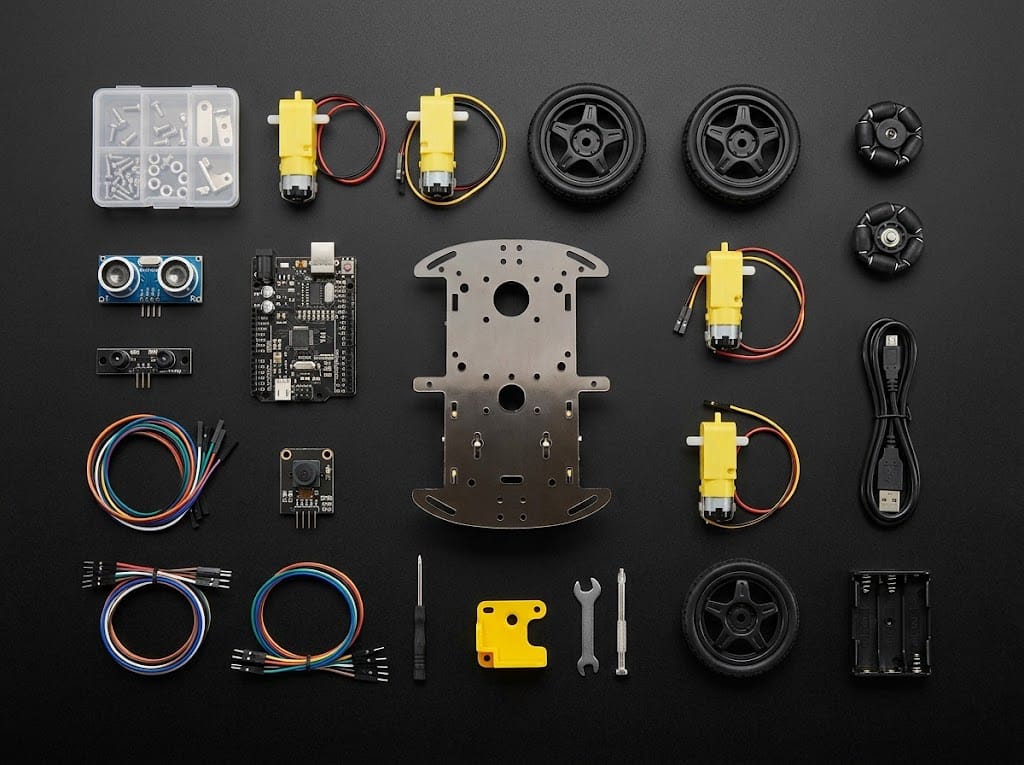
Robotics kit components laid out on a dark surface

04 — Service

Educational Robot Dog Kit

We are building an educational robot dog that grows with the learner. The same robot adapts to three levels of complexity, each with its own curriculum.

  • Schools: program it directly on a microcontroller
  • Universities: add a Raspberry Pi, ROS 2 and vision
  • Enthusiasts: train and deploy your own RL walking policies
  • Lesson plans and teacher support in Astana
  • In development — join the waitlist

For: Schools, universities and makers

How We Work

Four clear stages from your idea to a robot doing the job — you always know where we are.

  1. 01
    Stage 01 · Kickoff

    Discovery call

    You tell us about the robot, the task and the deadline. We tell you honestly what is realistic.

    You get: An honest yes / no / maybe

  2. 02
    Stage 02 · Plan

    Feasibility & plan

    We test the riskiest part in simulation first and turn it into a scoped plan with milestones.

    You get: A scoped plan with milestones

  3. 03
    Stage 03 · Build

    Build & iterate

    Weekly demos on real hardware. You see progress on video, not in slide decks.

    You get: Weekly video demos on your robot

  4. 04
    Stage 04 · Ship

    Handover

    Clean code, documentation and a training session so your team can run and extend the work.

    You get: Code, docs and a trained team

Have a robot and an idea? Let's make it work.